Classify Tunnel Points
Function Overview
Classify Tunnel Points is designed for 3D laser point cloud data of mine tunnels. Based on a deep learning model, it performs automatic semantic classification of point clouds and maps original point cloud classes to five target classes: tunnel wall, ventilation duct, cable, debris, and noise. GPU acceleration is supported for batch inference.
Usage
Click Mine > Classify Tunnel Points.
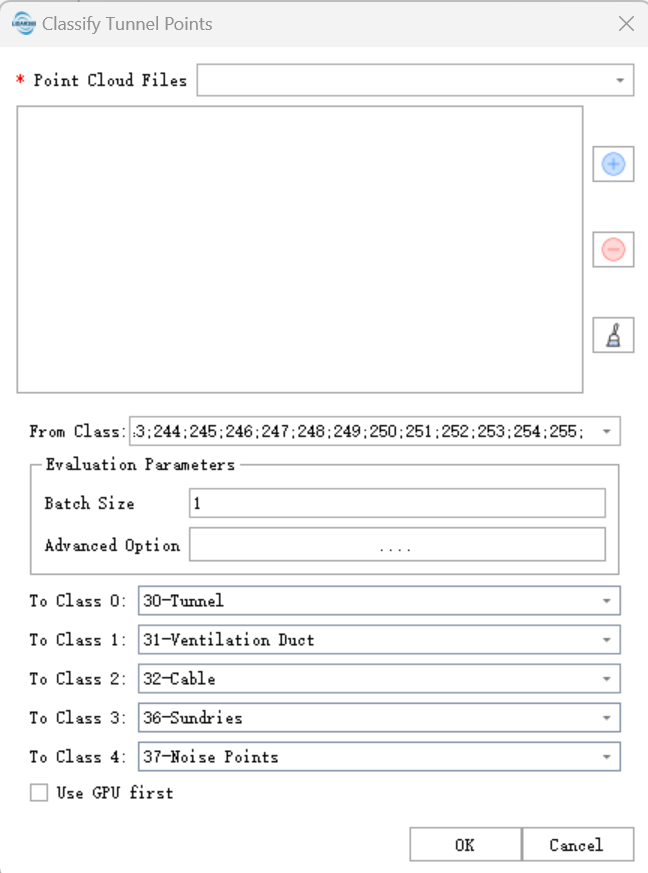
Parameter Settings
Point Cloud File: Add tunnel point clouds. Multiple files can be queued for processing.
Source Class: Select the source class involved in classification. The model only predicts points in the selected source classes. Points outside the selected source classes keep their original classes.
Batch Size: Number of point cloud sampling blocks processed by the model at one time. A larger value loads more data into GPU memory or system memory. The default value is 1.
Advanced Options: Five models are supported:
miou,macc,acc,latest.acc(overall accuracy) reflects overall classification correctness but is sensitive to class imbalance.macc(mean class accuracy) averages accuracy across classes and better evaluates minority classes.miou(mean intersection over union) is a core semantic segmentation metric that evaluates both class prediction and spatial boundary accuracy. A higher value indicates more reliable segmentation.latestis the most recently saved checkpoint and is not guaranteed to have the best performance.miouis recommended.Target Class: Five target classes are supported: tunnel wall, ventilation duct, cable, debris, and noise.
Prefer GPU: Prefer GPU for inference.
Note:
This function overwrites the original data file.